Buy empfehlung.eu ?
We are moving the project
empfehlung.eu .
Are you interested in purchasing the domain
empfehlung.eu ?
domain@kv-gmbh.de · 0541-91531010
Buy empfehlung.eu ?
What is kinematic physics?
Kinematic physics is the branch of physics that deals with the motion of objects without considering the forces that cause the motion. It focuses on describing the position, velocity, and acceleration of objects as they move through space and time. Kinematic equations are used to analyze and predict the motion of objects, and they are essential for understanding the behavior of moving bodies in various physical systems. This branch of physics is fundamental for understanding the basic principles of motion and is often a starting point for studying more complex topics in physics. **
How do you establish kinematic constraints?
Kinematic constraints are established by defining the relationships between the motion of different parts of a system. This can be done by specifying the allowable range of motion for each part, as well as any restrictions on their relative positions or velocities. Kinematic constraints can also be implemented through mathematical equations that describe the relationships between the motion variables of the system. By carefully defining these constraints, we can accurately model the behavior of the system and predict its motion under different conditions. **

Similar search terms for Kinematic
Top-Angebote
Products related to Kinematic:
-
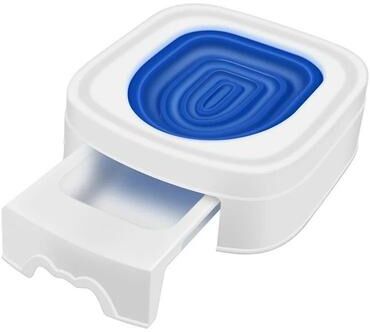
Uplift Essentials Independent Fixed Point Pet Toilet Guidance Trainer blueTransition your pet away from messy disposable pads and take the stress out of home housebreaking with a professional, reusable training system. This premium cat and dog toilet guidance trainer provides a structured, fixedpoint sandbox solution that...132,97 $*Shipping: 0,00 $Secure redirect to the provider
-
Uplifted Finds Independent Cat And Dog Toilet Guidance Trainer blueEmpower your pet with the ultimate hygiene independence using this premium cat and dog toilet guidance trainer. Expertly engineered to guide cats and small dogs toward using a fixedpoint sanitary tray or human restroom setup, this innovative...186,97 $*Shipping: 0,00 $Secure redirect to the provider
-
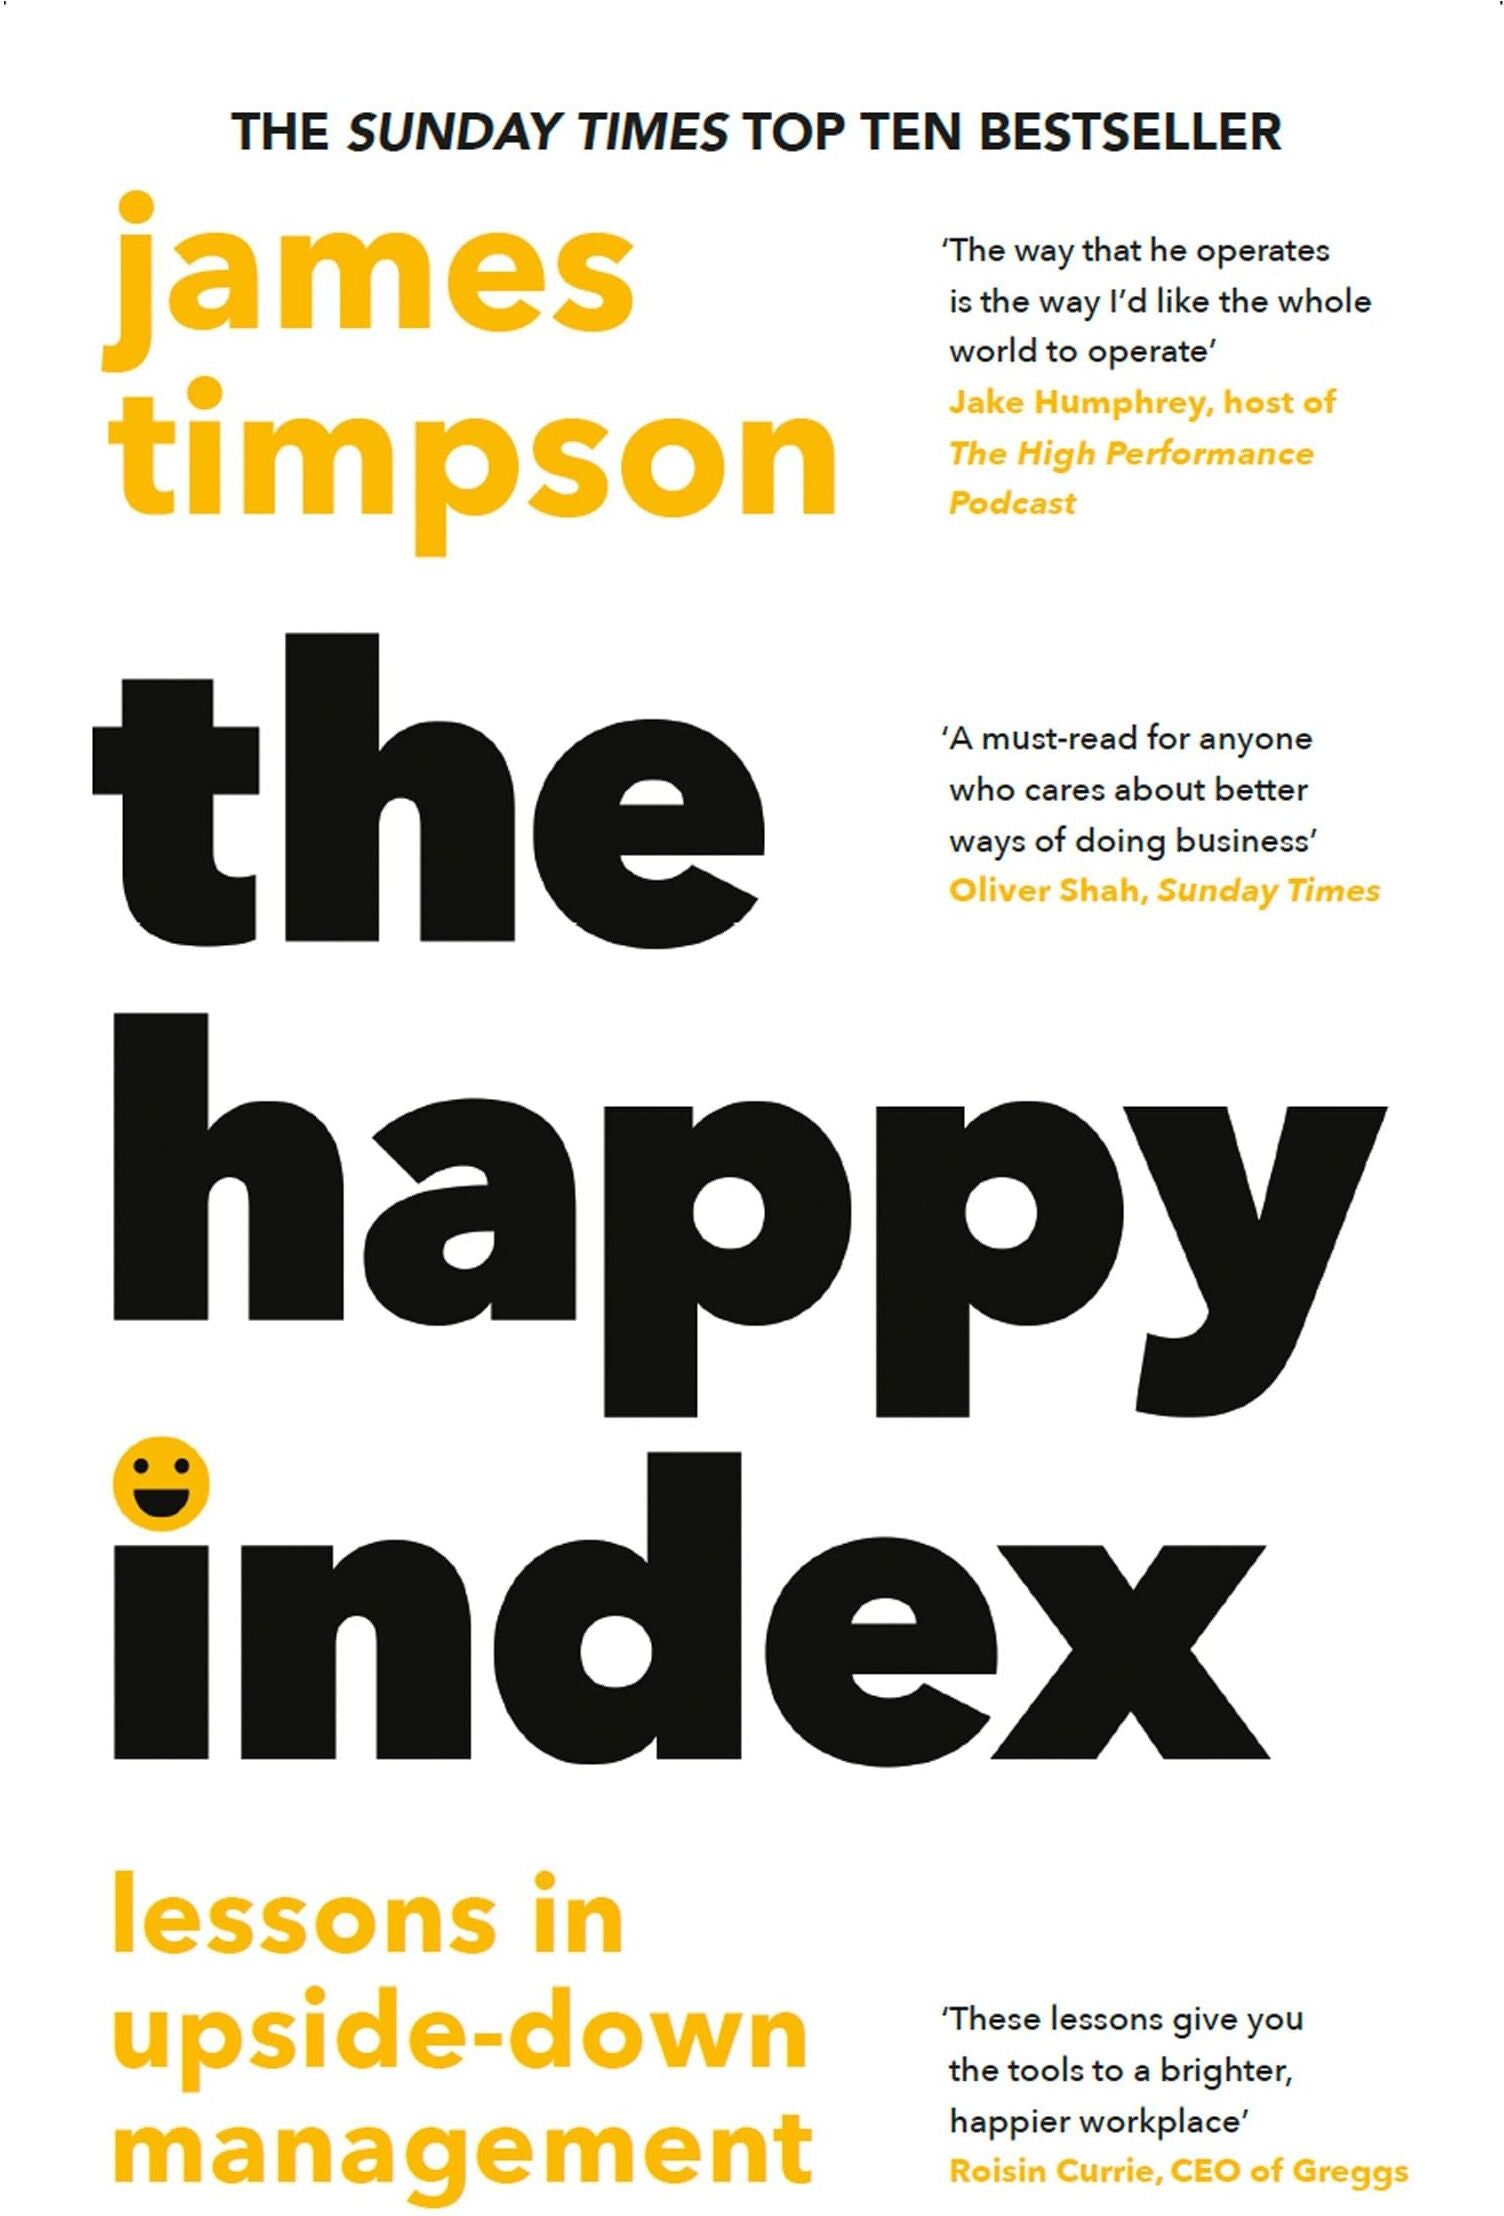
HarperNorth The Happy Index: Bestselling practical leadership advice for a happier workforce and better results by James TimpsonJames Timpson is renowned for leading with empathy and understanding, often by example. His acclaimed people-first approach to management empowers colleagues, putting measurable job satisfaction at the heart of corporate strategy. The Happy Index invites readers into a world where employee happiness isn't just a buzzword – it's a powerful catalyst for success that should be at the core of any successful organisation. Drawing on his decades of experience leading one of Britain’s best-loved high-street brands, Timpson shares the secrets behind his unique approach to ‘upside-down’ management. His infectious passion for people shines through every page and in the very real measures he has introduced – from days off for birthdays to free-to-use luxury holiday homes. And with a workforce comprised of at least 10 per cent ex-offenders at any one time, Timpson shows the value of an imaginative approach to hiring, with a staff retention rate to be proud of. From a leader who knows what it takes to build thriving organisations, The Happy Index gives companies, start-ups and leaders the tools they need to bring Timpson’s revolutionary approach to their working lives.8,99 £*Shipping: 2,99 £Secure redirect to the provider


-
How do you set up kinematic constraints?
To set up kinematic constraints, you first need to identify the relationship between the objects or parts that you want to constrain. Then, you can use software tools such as CAD programs or physics engines to define the constraints based on this relationship. Common types of kinematic constraints include revolute joints, prismatic joints, and fixed joints, which restrict the motion of the objects in specific ways. By applying these constraints, you can simulate realistic movements and interactions between the objects in your system. **
-
How do you achieve the kinematic relationship?
The kinematic relationship can be achieved by understanding the motion and position of objects in a system. This involves analyzing the velocity, acceleration, and displacement of the objects over time. By using mathematical equations and principles of physics, such as the equations of motion and Newton's laws, the kinematic relationship can be determined. Additionally, experimental data and observations can be used to validate and refine the kinematic relationship. **
-
How can one reach the kinematic relationship 3?
To reach the kinematic relationship 3, one can use the principles of kinematics to analyze the motion of objects. This involves studying the position, velocity, and acceleration of the objects and using equations and formulas to establish the relationships between these variables. Additionally, one can use graphical methods, such as velocity-time and position-time graphs, to visualize and understand the kinematic relationships. Finally, conducting experiments and collecting data can help to validate and confirm the kinematic relationships. **
-
Can you help me with a kinematic problem in physics?
Yes, I can help you with a kinematic problem in physics. Kinematics deals with the motion of objects without considering the forces that cause the motion. If you provide me with the specific details of the problem, such as the initial and final positions, velocities, accelerations, and time, I can help you solve for the unknown quantities using the kinematic equations. Feel free to ask me any specific questions you have about the problem, and I'll do my best to assist you. **

What is the solution method for kinematic problems in physics?
The solution method for kinematic problems in physics involves using the equations of motion to analyze the motion of an object. These equations include the equations for constant velocity, constant acceleration, and projectile motion. By identifying the known and unknown variables, such as initial velocity, final velocity, acceleration, displacement, and time, we can use the appropriate equation to solve for the unknown variable. It is important to carefully consider the given information and choose the correct equation to use in order to accurately solve kinematic problems in physics. **
Could someone explain or break down the transformation of this kinematic formula for me?
Sure! The kinematic formula that describes the relationship between initial velocity (u), final velocity (v), acceleration (a), and displacement (s) is given by the equation: v^2 = u^2 + 2as. This formula can be derived from the equations of motion by using the equation v = u + at and the equation s = ut + (1/2)at^2. By substituting the expression for t from the first equation into the second equation and then substituting the resulting expression for s into the equation v = u + at, we can arrive at the kinematic formula v^2 = u^2 + 2as. This formula is commonly used to solve problems involving motion under constant acceleration. **
Top-Angebote
Products related to Kinematic:
-
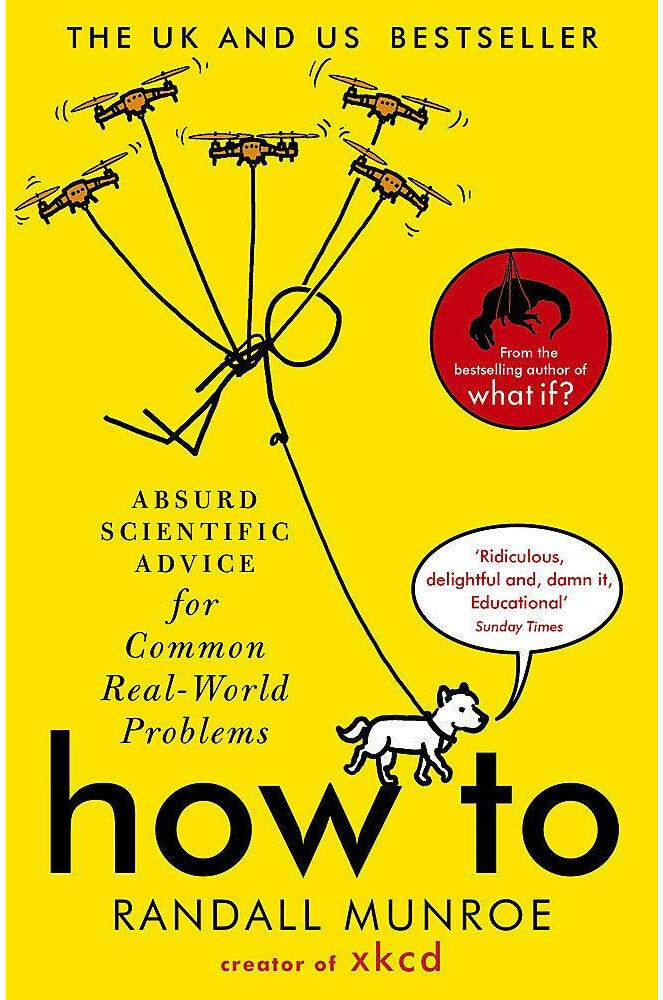
John Murray How To: Absurd Scientific Advice for Common Real-World Problems from Randall Munroe of xkcdThe world's most entertaining and useless self-help guide, from the brilliant mind behind the wildly popular webcomic xkcd and the million-selling What If? and Thing Explainer For any task you might want to do, there's a right way, a wrong way, and a way so monumentally bad that no one would ever try it. How To is a guide to the third kind of approach. It's full of highly impractical advice for everything from landing a plane to digging a hole.4,90 £*Shipping: 1,99 £Secure redirect to the provider
-
Uplift Essentials Independent Fixed Point Pet Toilet Guidance Trainer blueTransition your pet away from messy disposable pads and take the stress out of home housebreaking with a professional, reusable training system. This premium cat and dog toilet guidance trainer provides a structured, fixedpoint sandbox solution that...132,97 $*Shipping: 0,00 $Secure redirect to the provider
-
Uplifted Finds Independent Cat And Dog Toilet Guidance Trainer blueEmpower your pet with the ultimate hygiene independence using this premium cat and dog toilet guidance trainer. Expertly engineered to guide cats and small dogs toward using a fixedpoint sanitary tray or human restroom setup, this innovative...186,97 $*Shipping: 0,00 $Secure redirect to the provider
-
What is kinematic physics?
Kinematic physics is the branch of physics that deals with the motion of objects without considering the forces that cause the motion. It focuses on describing the position, velocity, and acceleration of objects as they move through space and time. Kinematic equations are used to analyze and predict the motion of objects, and they are essential for understanding the behavior of moving bodies in various physical systems. This branch of physics is fundamental for understanding the basic principles of motion and is often a starting point for studying more complex topics in physics. **
-
How do you establish kinematic constraints?
Kinematic constraints are established by defining the relationships between the motion of different parts of a system. This can be done by specifying the allowable range of motion for each part, as well as any restrictions on their relative positions or velocities. Kinematic constraints can also be implemented through mathematical equations that describe the relationships between the motion variables of the system. By carefully defining these constraints, we can accurately model the behavior of the system and predict its motion under different conditions. **
-
How do you set up kinematic constraints?
To set up kinematic constraints, you first need to identify the relationship between the objects or parts that you want to constrain. Then, you can use software tools such as CAD programs or physics engines to define the constraints based on this relationship. Common types of kinematic constraints include revolute joints, prismatic joints, and fixed joints, which restrict the motion of the objects in specific ways. By applying these constraints, you can simulate realistic movements and interactions between the objects in your system. **
-
How do you achieve the kinematic relationship?
The kinematic relationship can be achieved by understanding the motion and position of objects in a system. This involves analyzing the velocity, acceleration, and displacement of the objects over time. By using mathematical equations and principles of physics, such as the equations of motion and Newton's laws, the kinematic relationship can be determined. Additionally, experimental data and observations can be used to validate and refine the kinematic relationship. **
Similar search terms for Kinematic
-
HarperNorth The Happy Index: Bestselling practical leadership advice for a happier workforce and better results by James TimpsonJames Timpson is renowned for leading with empathy and understanding, often by example. His acclaimed people-first approach to management empowers colleagues, putting measurable job satisfaction at the heart of corporate strategy. The Happy Index invites readers into a world where employee happiness isn't just a buzzword – it's a powerful catalyst for success that should be at the core of any successful organisation. Drawing on his decades of experience leading one of Britain’s best-loved high-street brands, Timpson shares the secrets behind his unique approach to ‘upside-down’ management. His infectious passion for people shines through every page and in the very real measures he has introduced – from days off for birthdays to free-to-use luxury holiday homes. And with a workforce comprised of at least 10 per cent ex-offenders at any one time, Timpson shows the value of an imaginative approach to hiring, with a staff retention rate to be proud of. From a leader who knows what it takes to build thriving organisations, The Happy Index gives companies, start-ups and leaders the tools they need to bring Timpson’s revolutionary approach to their working lives.8,99 £*Shipping: 2,99 £Secure redirect to the provider
-
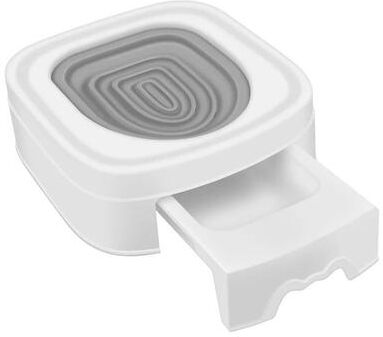
Uplift Essentials Independent Fixed Point Pet Toilet Guidance Trainer pinkTransition your pet away from messy disposable pads and take the stress out of home housebreaking with a professional, reusable training system. This premium cat and dog toilet guidance trainer provides a structured, fixedpoint sandbox solution that...132,97 $*Shipping: 0,00 $Secure redirect to the provider
-
Uplift Essentials Independent Fixed Point Pet Toilet Guidance Trainer greyTransition your pet away from messy disposable pads and take the stress out of home housebreaking with a professional, reusable training system. This premium cat and dog toilet guidance trainer provides a structured, fixedpoint sandbox solution that...132,97 $*Shipping: 0,00 $Secure redirect to the provider
-
How can one reach the kinematic relationship 3?
To reach the kinematic relationship 3, one can use the principles of kinematics to analyze the motion of objects. This involves studying the position, velocity, and acceleration of the objects and using equations and formulas to establish the relationships between these variables. Additionally, one can use graphical methods, such as velocity-time and position-time graphs, to visualize and understand the kinematic relationships. Finally, conducting experiments and collecting data can help to validate and confirm the kinematic relationships. **
-
Can you help me with a kinematic problem in physics?
Yes, I can help you with a kinematic problem in physics. Kinematics deals with the motion of objects without considering the forces that cause the motion. If you provide me with the specific details of the problem, such as the initial and final positions, velocities, accelerations, and time, I can help you solve for the unknown quantities using the kinematic equations. Feel free to ask me any specific questions you have about the problem, and I'll do my best to assist you. **
-
What is the solution method for kinematic problems in physics?
The solution method for kinematic problems in physics involves using the equations of motion to analyze the motion of an object. These equations include the equations for constant velocity, constant acceleration, and projectile motion. By identifying the known and unknown variables, such as initial velocity, final velocity, acceleration, displacement, and time, we can use the appropriate equation to solve for the unknown variable. It is important to carefully consider the given information and choose the correct equation to use in order to accurately solve kinematic problems in physics. **
-
Could someone explain or break down the transformation of this kinematic formula for me?
Sure! The kinematic formula that describes the relationship between initial velocity (u), final velocity (v), acceleration (a), and displacement (s) is given by the equation: v^2 = u^2 + 2as. This formula can be derived from the equations of motion by using the equation v = u + at and the equation s = ut + (1/2)at^2. By substituting the expression for t from the first equation into the second equation and then substituting the resulting expression for s into the equation v = u + at, we can arrive at the kinematic formula v^2 = u^2 + 2as. This formula is commonly used to solve problems involving motion under constant acceleration. **
* All prices are inclusive of VAT and, if applicable, plus shipping costs. The offer information is based on the details provided by the respective shop and is updated through automated processes. Real-time updates do not occur, so deviations can occur in individual cases. ** Note: Parts of this content were created by AI.